In mid-May 2026, I joined the teaching team of the intensive 3-day PhD course “Unmanned Aerial Vehicles (UAVs or Drones) in Research and Industry” (3 ECTS) at Aalborg University (CREATE Building, Rendsburggade 14). Organized by Associate Prof. Timothy Merritt with support from the Aalborg Robotics Platform, the course immersed 30 PhD candidates from across engineering, computer science, and environmental disciplines in the rapidly expanding domain of autonomous drone technology.A mediados de mayo de 2026 me uní al equipo docente del curso intensivo de doctorado de 3 días “Unmanned Aerial Vehicles (UAVs or Drones) in Research and Industry” (3 ECTS) en Aalborg University (CREATE Building, Rendsburggade 14), organizado por el Prof. Asociado Timothy Merritt con apoyo de la Aalborg Robotics Platform. El curso reunió a 30 doctorandos de ingeniería, informática y ciencias ambientales en el ámbito de la tecnología de drones autónomos.


📚 3-Day Curriculum Breakdown📚 Programa de 3 días
The curriculum combined state-of-the-art research lectures, critical paper analysis, hands-on flight labs, and official A1/A3 EU drone pilot certification:El programa combinó ponencias punteras, análisis crítico de papers, prácticas de vuelo y la certificación oficial A1/A3 de piloto de drones de la UE:
Day 1: Fundamentals, Critical Environments & Industrial DronesDía 1: fundamentos, entornos críticos y drones industriales
- Drones 101 & Flight Physics: Introduction to UAS platforms, aerodynamics, and regulation reviews led by ENAC researchers.Drones 101 & Flight Physics: Introducción a las plataformas UAS, aerodinámica y normativas con investigadores de ENAC.
- Indoor Flight Practice: Hands-on indoor piloting sessions in the CREATE atrium with multi-rotor micro-drones.Indoor Flight Practice: Sesiones prácticas de pilotaje en el atrio del CREATE con micro-drones multirrotor.
- Industrial Case Studies: Kenneth Geipel (CEO, Robotto.ai) showcased real-world commercial drone deployments across wildfire tracking, environmental surveillance, SAR logistics, and defense.Industrial Case Studies: Kenneth Geipel (CEO, Robotto.ai) mostró despliegues comerciales reales de drones: seguimiento de incendios, vigilancia ambiental, logística SAR y defensa.
Day 2: Multi-Drone Swarms & Human-Drone Interaction (HDI)Día 2: enjambres multi-drone e interacción humano-drone
- State of the Art in Multi-UAV Systems: Prof. Anders Lyhne Christensen (SDU UAS Center) detailed decentralized swarm algorithms, emergent behaviors, and collaborative spatial sensing.State of the Art in Multi-UAV Systems: Anders Lyhne Christensen (SDU UAS Center) detalló algoritmos de enjambre descentralizados, conductas emergentes y sensado espacial conjunto.
- Room-Scale Drone Interactions: Tim Merritt presented research on micro-drones operating in close proximity to humans.Room-Scale Drone Interactions: Tim Merritt presentó investigación sobre micro-drones operando muy cerca de personas.
- Human-Drone Interaction & Accessibility: Anke Brock and Prof. Jessica Cauchard (TU Wien) presented Drones4Good — exploring how UAVs can support people with impairments and enable intuitive spatial navigation.Human-Drone Interaction & Accessibility: Anke Brock y la Prof. Jessica Cauchard (TU Wien) mostraron Drones4Good: cómo los UAVs ayudan a personas con discapacidad y facilitan la navegación espacial intuitiva.
- User Interfaces for Multi-Robot Systems: Maria-Theresa Bahodi explored dashboard ergonomics and operator cognitive load.User Interfaces for Multi-Robot Systems: Maria-Theresa Bahodi exploró la ergonomía de paneles y la carga del operador.
Day 3: LLM Swarm Control, A1/A3 Exam & Harbour DemoDía 3: control de enjambres con LLM, A1/A3 y demo
- A1/A3 Open Category Pilot Exam: Preparation and official certification test facilitated by Toke Suhr (Droner.dk).A1/A3 Open Category Pilot Exam: Preparación y examen oficial de certificación con Toke Suhr (Droner.dk).
- Cooperative One Search Agent (OSA): Juan Bravo-Arrabal presented algorithms integrating real-time sensor perception into automated search decision-making.Cooperative One Search Agent (OSA): Juan Bravo-Arrabal presentó algoritmos integrando lectura de sensores en tiempo real en la búsqueda automatizada.
- LLM-Driven HCI for Multi-Drone Fleets: I presented our work on natural-language voice control for multi-robot teams.LLM-Driven HCI for Multi-Drone Fleets: Presenté nuestro trabajo de control por voz natural para equipos multi-robot.
- Live Outdoor Demonstration: Weather permitting over the Aalborg waterfront harbor, our team demonstrated live voice-commanded multi-UAV flight execution and telemetry-grounded intent parsing.Live Outdoor Demonstration: Si el tiempo lo permitía, junto al puerto de Aalborg, demostramos vuelo multi-UAV por comandos de voz y parsing de intención basado en telemetría.
🗣️ My Lecture: LLM-Enabled Voice Command of Multi-Robot Systems🗣️ Mi ponencia: control por voz de sistemas multi-robot con LLM
In my session, I walked students through how we bridge natural human speech and physical robotic actuation (Figure 1):En mi sesión expliqué cómo unimos el habla humana natural y la actuación robótica física (Figure 1):
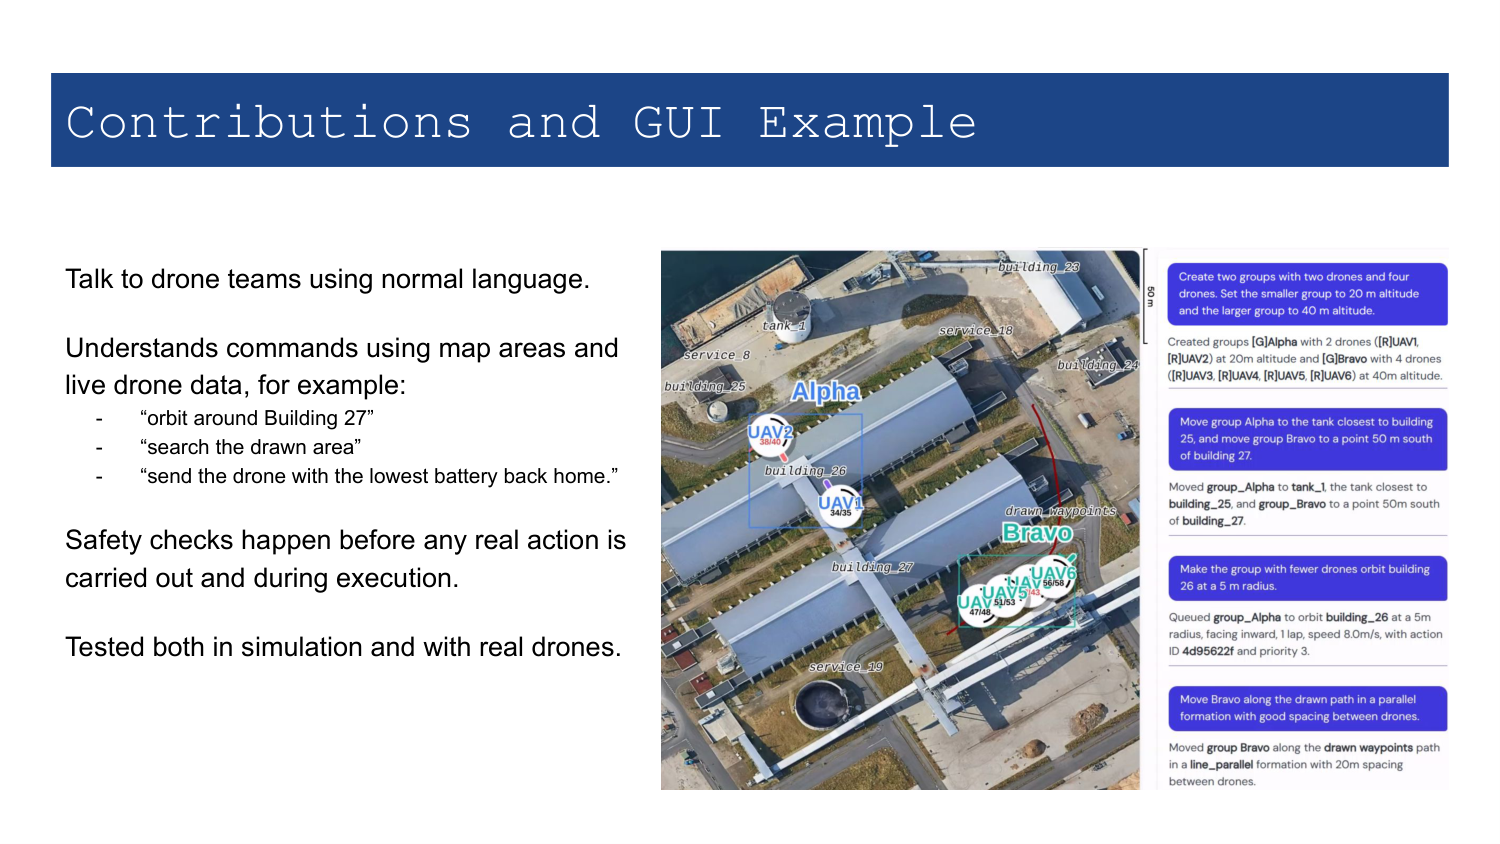
- The Core Bottleneck: Why manual multi-robot control causes cognitive overload during high-pressure emergency missions, and how conversational LLM interfaces empower non-experts to command complex fleets naturally.The Core Bottleneck: Por qué el control manual multi-robot causa sobrecarga cognitiva en emergencias críticas, y cómo las interfaces con LLM permiten a no expertos comandar flotas complejas de forma natural.
- Tool-Augmented LLM Agents: Overcoming knowledge cutoffs and spatial calculation limits by coupling auto-regressive models with deterministic geographic and telemetry tools.Tool-Augmented LLM Agents: Superar knowledge cutoffs y límites de cálculo espacial acoplando modelos auto-regresivos a herramientas deterministas de geografía y telemetría.
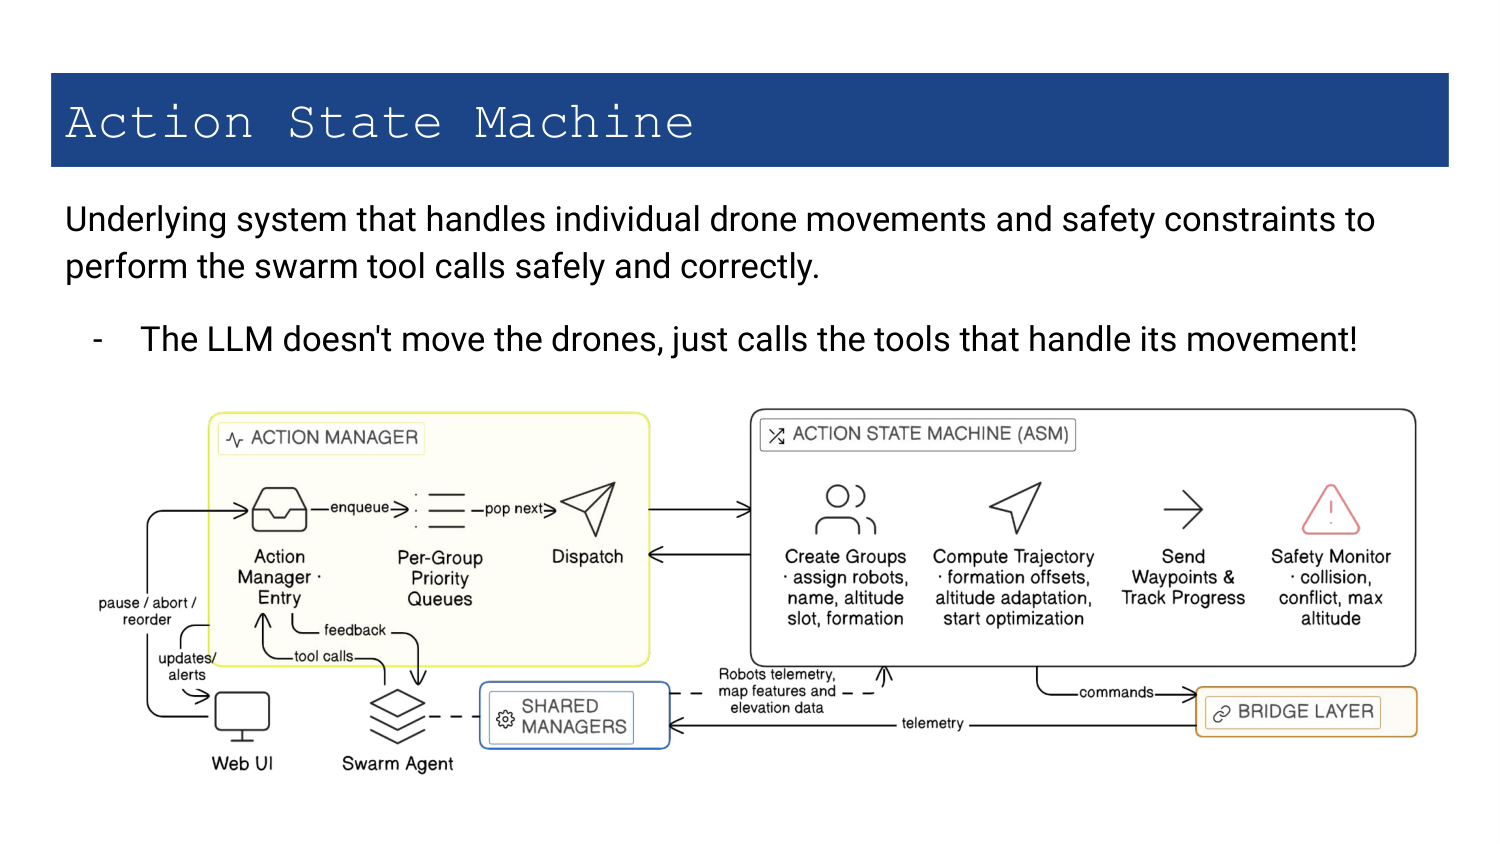
- Deterministic Execution via State Machines (Figure 2): Why LLMs must never directly drive motors — our architecture decouples high-level intent parsing from an underlying deterministic action state machine that enforces speed, battery, and airspace safety invariants.Deterministic Execution via State Machines (Figure 2): Por qué los LLMs nunca deben controlar motores directamente — la arquitectura separa el parsing de intención de una state machine determinista que impone invariantes de velocidad, batería y espacio aéreo.
Real-World Validations PresentedValidaciones en entornos reales
I illustrated our progression through three real-world deployment milestones:Ilustré nuestra progresión con tres hitos de despliegue real:
- JEMERG 2025 (Málaga, Spain): Deploying a voice-commanded UGV for critical medical and battery delivery across six emergency scenarios with 150+ first responders (SSRR 2025 Best Paper Finalist).JEMERG 2025 (Málaga, España): UGV controlado por voz para entrega crítica de material y baterías en seis emergencias con 150+ primeros intervinientes (finalista Best Paper SSRR 2025).
- Swarm-Steward at Ol Pejeta (Kenya): Deploying up to 5 autonomous DJI Mini 4 Pro drones for AI-driven rhino search under dense savanna vegetation during the WildDrone Hackathon.Swarm-Steward at Ol Pejeta (Kenya): Hasta 5 drones autónomos DJI Mini 4 Pro para buscar rinocerontes con IA bajo la vegetación de la sabana durante el WildDrone Hackathon.
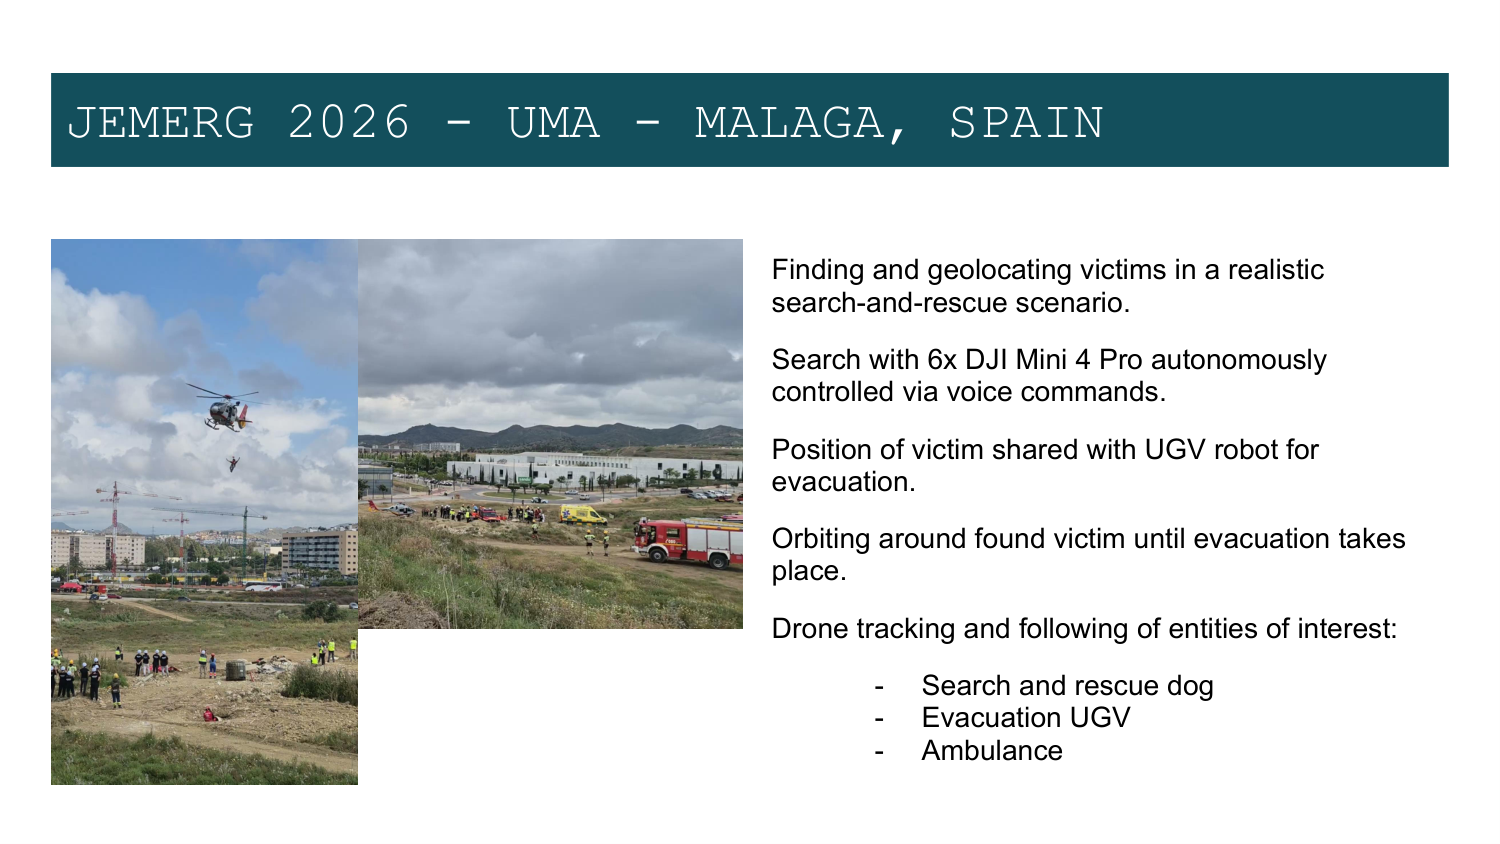
- JEMERG 2026 (Málaga, Spain — Figure 3): Multi-UAV victim search, automated victim geolocation, perimeter orbiting, and ground rover evacuation handoffs.JEMERG 2026 (Málaga, España — Figure 3): Búsqueda multi-UAV de víctimas, geolocalización automática, órbita perimetral y evacuación al rover.
May 2026 · Aalborg PhD CourseMay 2026 · Curso PhD Aalborg Lecture Slides PDFSlides de ponencia AAU CREATEAAU CREATE Aalborg RoboticsAalborg Robotics
The PhD course “UAVs in Research and Industry” (3 ECTS) is organized biennially by the Department of Computer Science at Aalborg University.El curso “UAVs in Research and Industry” (3 ECTS) se organiza cada dos años en el Department of Computer Science de Aalborg University.